01 / Steer the beam
Keep the target at 20° and steer the beam from −60° to 60°. Compare the single-microphone and array outputs: when is the target clearest?
The scan uses the selected harmonic frequency. Two mutually incoherent sources are added at equal power, then normalised to the scan maximum. Directional response indicators use a unit coherent-response reference; neither quantity is a sound pressure level.
Audio includes the first ten blade-passing harmonics and broadband noise; loudness cannot be directly compared with the single-frequency scan. Start at low volume. Animation runs at 1/100 of the rotor speed, and distances are not to scale. Pausing animation does not stop audio.
Each blade passes the observation direction once per revolution. Therefore, the blade-passing frequency is BPF = Blade count × RPM / 60.For example, a three-bladed rotor at 6,000 rpm rpm gives a BPF of 300 Hz and a sixth harmonic of 1,800 Hz.Audio includes multiple harmonics; the analysed order changes only the scan frequency.
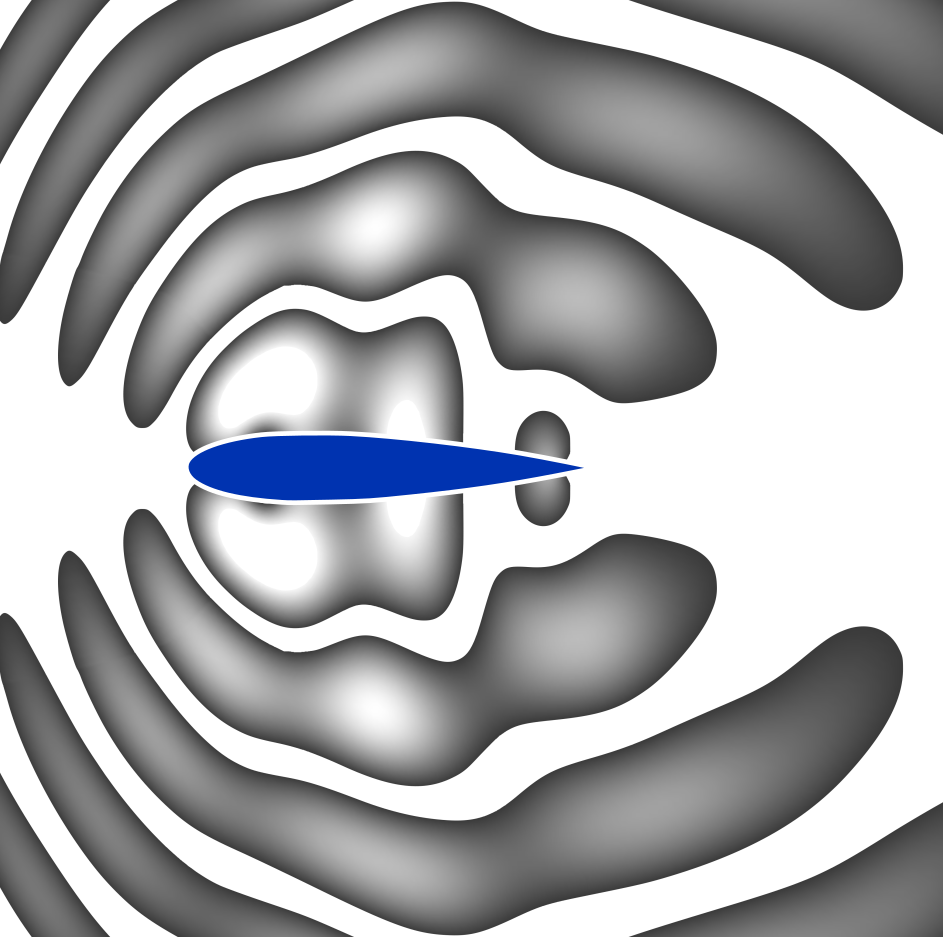
The rotor is represented by a far-field source in the direction of its hub. The animation shows blade motion, while the array identifies the direction of the rotor as a whole. It cannot resolve an individual blade or blade-tip noise hotspot. Pausing the animation does not stop the audio.
Sound from one direction reaches different microphones at different times. Compensating these delays and averaging adds the target signals coherently. Other directions are usually attenuated, although sidelobes or grating lobes may occur.
Here c = 343 m/s and θ₀ is the steering angle. A common delay is added to the audio to make all delays causal. Outputs are averaged without automatic loudness compensation so that directional suppression remains audible.
Up to six channels show the target centre-frequency component against time. Their phases align when the beam points at the target.
Keep the target at 20° and steer the beam from −60° to 60°. Compare the single-microphone and array outputs: when is the target clearest?
Select “Resolve adjacent sources” and increase the aperture. Check whether the scan resolves two peaks, while monitoring excessive microphone spacing.
Select “Observe spatial aliasing”. Increase the microphone count or reduce the rotor speed or analysed harmonic order, and observe the false-direction peaks.
This experiment uses stationary, mutually incoherent far-field plane waves, an anechoic environment and ideal omnidirectional microphones. Rotor broadband noise and blade-passing harmonics are synthetic analogies only. Flow convection, shear-layer refraction, near-field spherical spreading, moving-source propagation, Doppler effects and instrument noise are not modelled. It does not predict sound pressure levels. A uniform linear array also has front–back ambiguity; only the front half-plane is shown.